Solutions
Three tools, one idea: precise 3D understanding without GNSS. RMAP is the platform, Multi-Agent 3D Mapping the capability at its core, and the Positioning Tool the application to known objects.
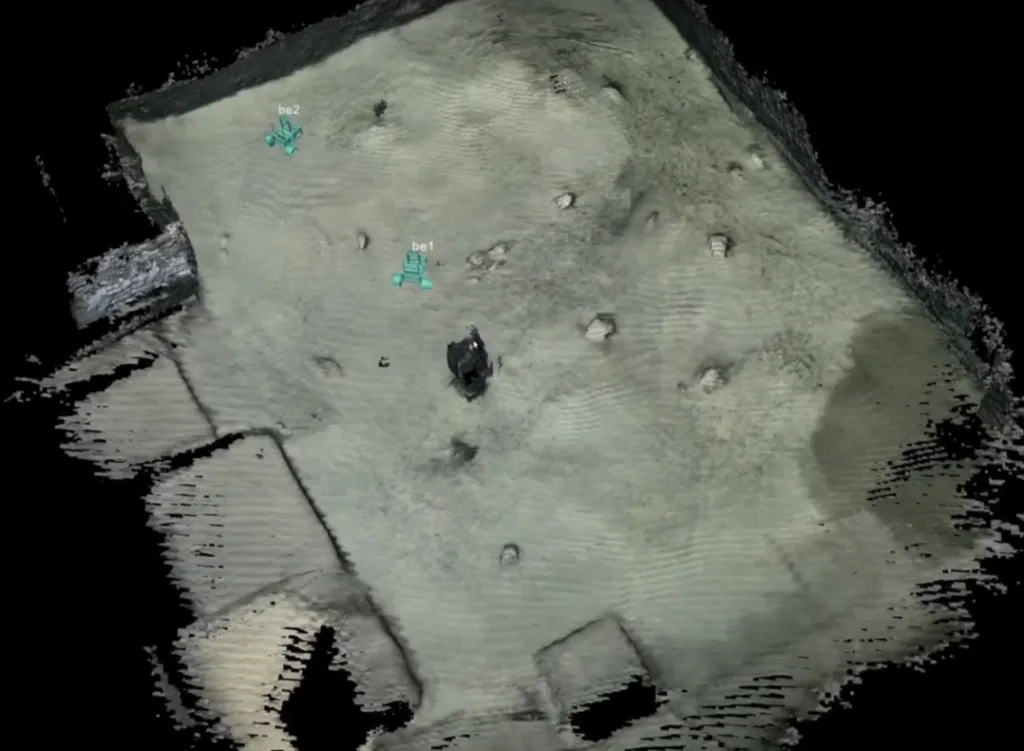
Multi-Agent 3D Mapping
The capability at RMAP’s core: multiple robots build one real-time 3D map from stereo vision.
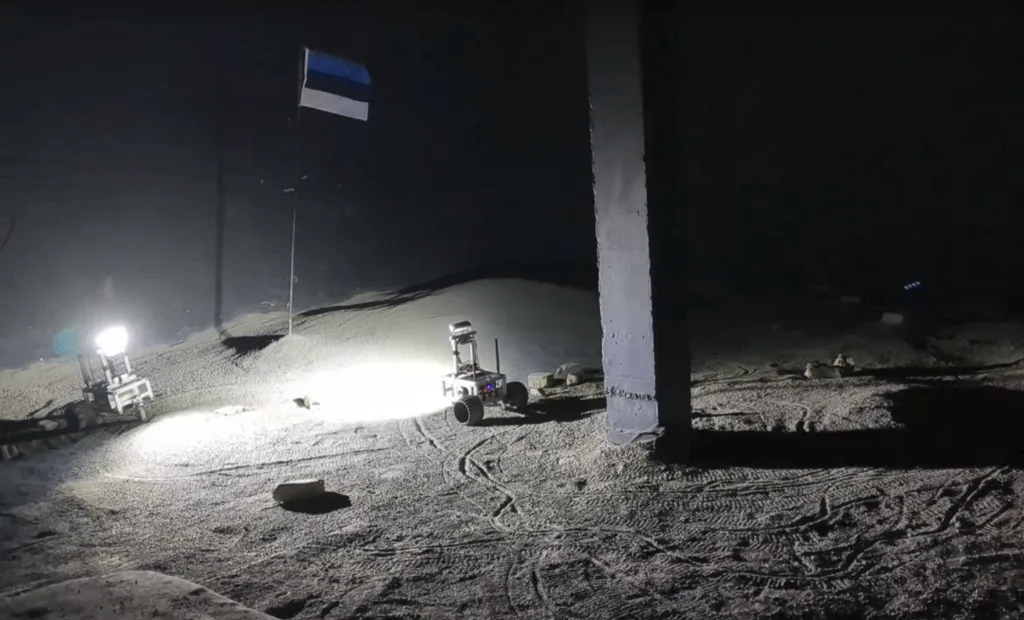
Resilient Multi-Agent Autonomy Platform
The platform: a decentralized SDK and operator dashboard that keeps a robot team on one shared map.
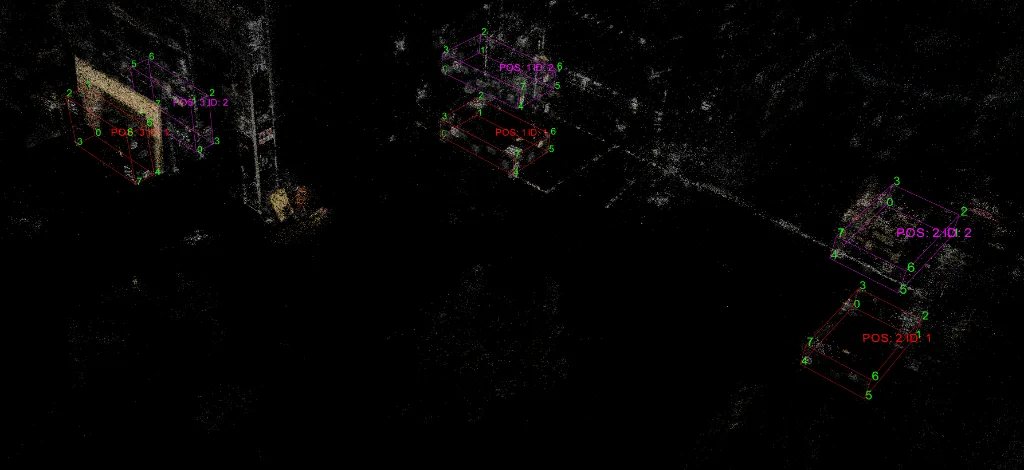
Taara Positioning Tool
Calibrate an object from photos, then localize it precisely within any environment.